Device Driver Development: What It Is and Why It Decides Reliability
How embedded device drivers work, where Linux and RTOS drivers differ, common failure modes, and how to test drivers before hardware ships.
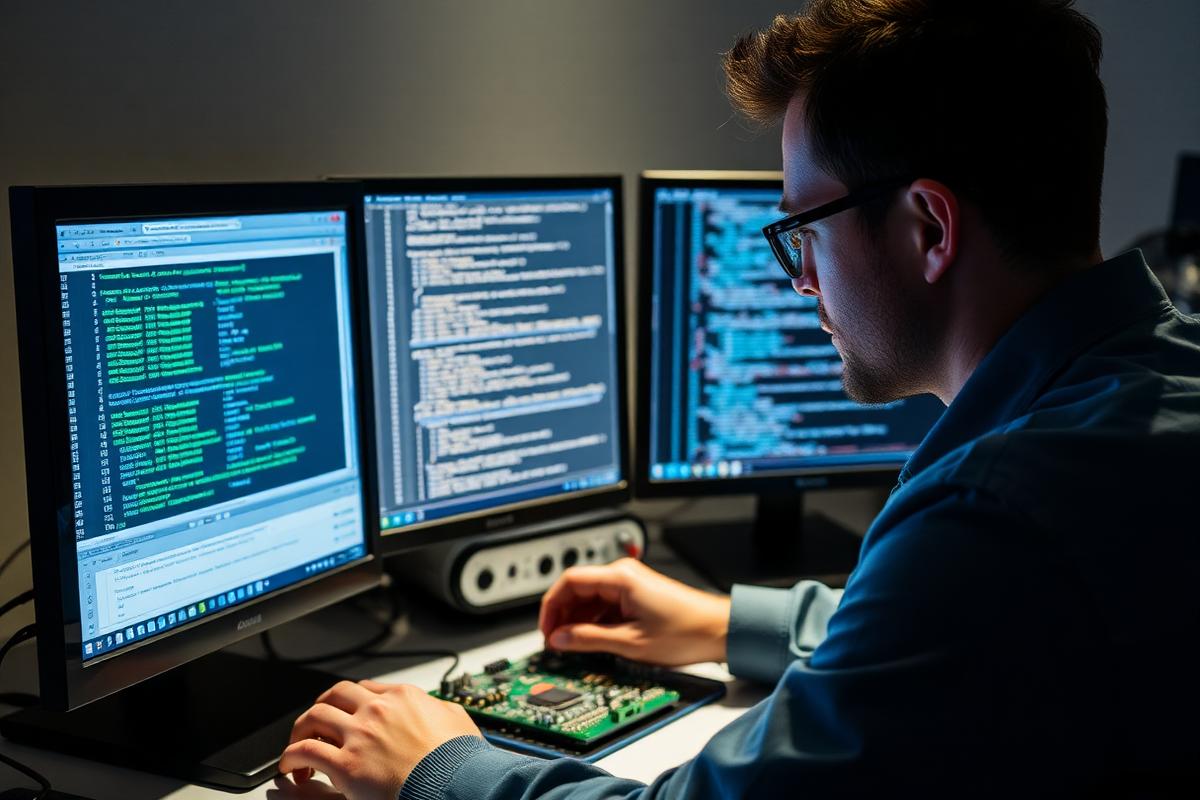
A driver is the translation layer between your application and a piece of silicon. When products behave strangely in the field — random resets, missing sensor data, devices that hang overnight — the cause is usually here.
What a driver actually does
- Initialises the peripheral and its clocks, pins and power domains.
- Handles interrupts quickly and defers the slow work.
- Exposes a clean API so the application never touches registers.
- Recovers from bus errors, timeouts and unexpected disconnects.
Linux vs RTOS vs bare metal
Linux kernel modules bring a mature driver model and userspace interfaces but demand strict kernel discipline. RTOS and bare-metal drivers are leaner and more deterministic, and put the whole burden of correctness on you.
Where drivers usually break
- Blocking work inside an interrupt service routine.
- Shared state without protection between ISR and task context.
- No timeout on I2C, SPI or UART transactions.
- Assuming the peripheral always powers up in a known state.
Test before the hardware exists
Abstract the hardware layer so the driver can run against a simulated peripheral, add a logic analyser to the bring-up bench, and script long-running soak tests. Bugs that appear after 40 hours are the ones that reach customers.
Want this done for your business?
KAF Infotech LLP builds websites, apps, ERP systems and connected products from Mumbai.